Robot manipulation is difficult because objects vary in shape, weight, stiffness, and surface friction. Recognizing an object doesn’t tell a robot how to grasp it securely or adjust when it slips or bends.
On a warehouse floor, a rigid box and a flexible shipping bag can require different handling strategies. The robot must make suitable contact, control its grip, and move each package without damage.
Anthropic’s “What work can robots do?”, published September 30, 2026, estimates robots can perform 74% of US physical work. This time-weighted estimate represents 34% of all working hours, with performance often limited to controlled settings. Robots are estimated to be cost-competitive for only 0.3% of total working time.
On manipulation, the report states: “half of physical tasks wouldn’t be automated at scale unless robots become more adept at touching and handling objects.”
This article explains the object-handling challenges and what training data and annotation can contribute.
What Is Robot Manipulation?
Robot manipulation is the controlled physical interaction a robot uses to move or change objects. It covers more than picking something up:
- Grasping and placing: Moving an item from a conveyor into a shipping container.
- Pushing and sliding: Repositioning an object without lifting it.
- Turning and inserting: Rotating a handle or fitting a component into an assembly.
A successful grasp is only one step. The robot must also plan a reachable path and control the object throughout the movement. Placing a component may require precise alignment, while inserting it may require responding to contact forces.
Russ Tedrake’s MIT course, “Robotic Manipulation”, covers how perception, planning, and control work together. Perception supplies information about the scene. Planning determines a course of action. Control adjusts the robot’s motion and, where needed, the forces it applies.
Why Do Different Objects Create Different Challenges?
A grasp that works for one item may fail on another. The robot’s gripper, the available contact surfaces, and the object’s orientation all affect its options.
Shape and grasp position
Imagine picking up a mug beside a wall. Its handle offers a possible grasp, but the wall may block the gripper’s approach. Grasping the body requires enough opening width and suitable contact points.
For a gripper with two opposing fingers, grasp selection involves checking:
- Contact surfaces: Can the fingers establish a stable hold?
- Gripper width: Does the selected part fit between the fingers?
- Clearance: Can the gripper approach and close without colliding with its surroundings?
Ma et al.’s CVPR 2024 study examined grasp detection on objects with unfamiliar shapes and structures. The researchers reported reduced performance on these objects and improved predictions by incorporating physical grasping constraints.
Weight, material, and grip force
Two containers can look identical but require different grip forces if one is empty and the other is full. For a friction-based grasp, greater weight generally requires more gripping force when contact geometry and surface friction remain unchanged.
Material adds another constraint:
- Low-friction surfaces: A slippery container may need greater gripping force or a different handling strategy.
- Fragile objects: Excessive pressure can damage the item, limiting how firmly the robot can squeeze.
- Flexible objects: A pouch can deform under pressure, changing the contact surfaces as the gripper closes.
These requirements can conflict. Squeezing harder may prevent slipping but crush a delicate object. Tedrake’s section “Static equilibrium with frictional contact” explains how friction and force balance affect stability. Choosing a grasp therefore involves understanding how the object responds to force, alongside its visible shape.
Position, clutter, and visibility
An object partly buried in a bin presents a different problem from one sitting alone. The camera may capture its top surface while neighboring items hide its sides and potential contact points.
This creates uncertainty about:
- Object boundaries: Which visible surfaces belong to the target item?
- Hidden geometry: What shape lies beneath the visible portion?
- Scene changes: What becomes visible after another item is removed?
Getting another view can help, but moving the camera takes time. Ma et al.’s NeurIPS 2024 study selected informative viewpoints to improve grasp detection in cluttered scenes. Their approach balanced grasping performance against observation time, rather than relying on a complete scene scan.
How Does Manipulation Limit the Work Robots Can Do?
Automating one step does not establish that a robot can complete an entire workflow. Moving standardized packages differs from unpacking them, separating loose contents, and assembling the parts inside.
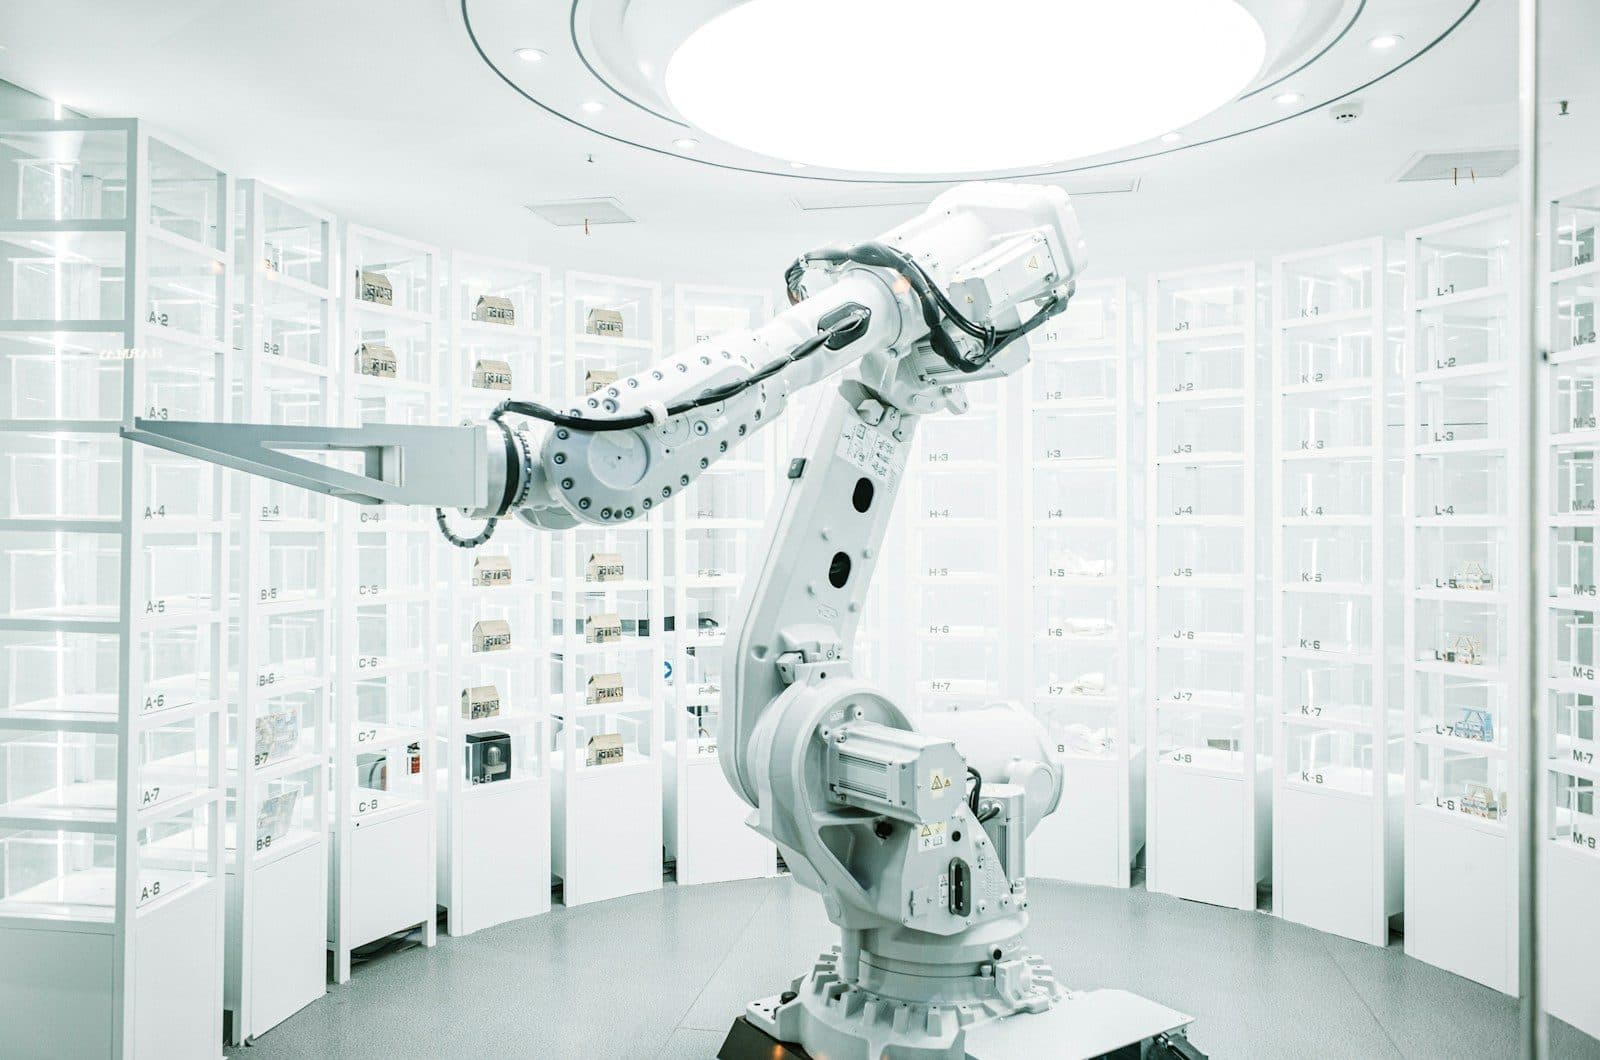
Anthropic illustrates this distinction through drywall work. Its assessment identifies robotic spraying and sanding capabilities. Embedding paper tape in wet compound is rated as something robots cannot do today. These tasks require different physical capabilities, even though they belong to the same job.
The environment also matters. The study estimates that half of physical tasks, weighted by working time, are achievable only in purpose-built robot environments. This measures capability under specific conditions, rather than how much work has already been automated.
For example, a fixture can hold a component in a predictable position, simplifying the interaction. Removing that support introduces additional demands on perception and control.
Better manipulation could expand the tasks robots perform, but would not automatically make deployment economical. Robotics teams therefore need to identify the specific interaction preventing a workflow from succeeding, alongside its cost and operating constraints.
What Should Object-Handling Data and Annotations Capture?
If a robot drops an item after lifting it, “failed pick” records the outcome but leaves the cause unclear. Did it lose its grip during movement or release the object too early? Robot failure analysis investigates where an attempt broke down and why.
Recordings can help teams distinguish those cases when the camera views and recorded signals capture the relevant events. Depending on the task and learning method, relevant records may include:
- Starting conditions: The target object, its orientation, nearby items, and intended destination.
- Executed actions: Gripper commands and robot motion aligned with camera observations.
- Contact information: Force or tactile readings, when available and relevant.
- Results: Whether the object was acquired, transported, and placed, including retries or human intervention.
Annotation can identify specific events within those records. A team investigating drops might mark confirmed acquisition, visible slipping, the object leaving the gripper, and final placement. These labels need clear definitions. Gripper closure alone does not confirm that an object was acquired.
Labelix.ai’s robotics data annotation guide explains how event timing and outcome labels structure robot recordings. For manipulation, the priority is choosing labels that answer the team’s specific training or evaluation question.
Collection and annotation serve different purposes. Labeling cannot create a missing force measurement or supply recordings of object variations absent from the dataset. Our guide to usable robotics datasets covers that broader collection problem.
Better labels also cannot compensate for every model limitation. The CVPR study discussed earlier used grasp labels alongside physical constraints during training to improve generalization. Its approach illustrates how data and model design can work together.
How Should a Team Start Building Object-Handling Data?
Choose one handling failure to investigate, then define what evidence would show improvement. Use that question to guide collection, annotation, and evaluation.
Labelix.ai helps Physical AI teams collect, organize, annotate, and quality-check real-world training data. For object-handling projects, that means defining the variations to capture and applying consistent labels to relevant actions and outcomes.
Have a handling task your robot struggles with? Contact Labelix.ai to discuss your object-handling data needs.
Have a handling task your robot struggles with?
Start with one object-handling task. A dedicated Labelix.ai team learns your labeling guideline and annotates the actions and outcomes in your recordings, in a small paid pilot.
FAQs
What is robot manipulation?
Robot manipulation is controlled physical interaction with objects. It includes grasping, placing, pushing, turning, and inserting. These tasks combine perception, planning, and control.
Why can a robot recognize an object but fail to pick it up?
Recognition identifies the object, but picking it up requires suitable contact points, a reachable approach, and a stable grip. Knowing what an object is does not reveal every physical property needed to handle it.
Why is grasping unfamiliar objects difficult for robots?
Unfamiliar objects can differ in shape, weight, surface friction, and stiffness. These differences affect where a robot can grasp and how much force it needs. Hidden surfaces add uncertainty.
How does clutter affect robot manipulation?
Clutter can hide an object's surfaces and block the gripper's approach. A robot may need another camera view or move neighboring items before it can reach and grasp the target safely.
What data helps robots learn to handle different objects?
Depending on the learning method, useful data may include camera observations, robot movements, gripper commands, and outcomes. Examples should cover relevant object variations. Force or tactile readings can add information about contact.
Stephanie writes about robotics, agriculture AI, and the training data behind them, for Labelix.ai, an independent data foundry for robotics and multimodal AI.
Get the next one first
One sharp read a month on Physical AI and the data behind it.