Labelix.ai Robot Lab: remote robot arms in Dhaka. Come and use the arm.
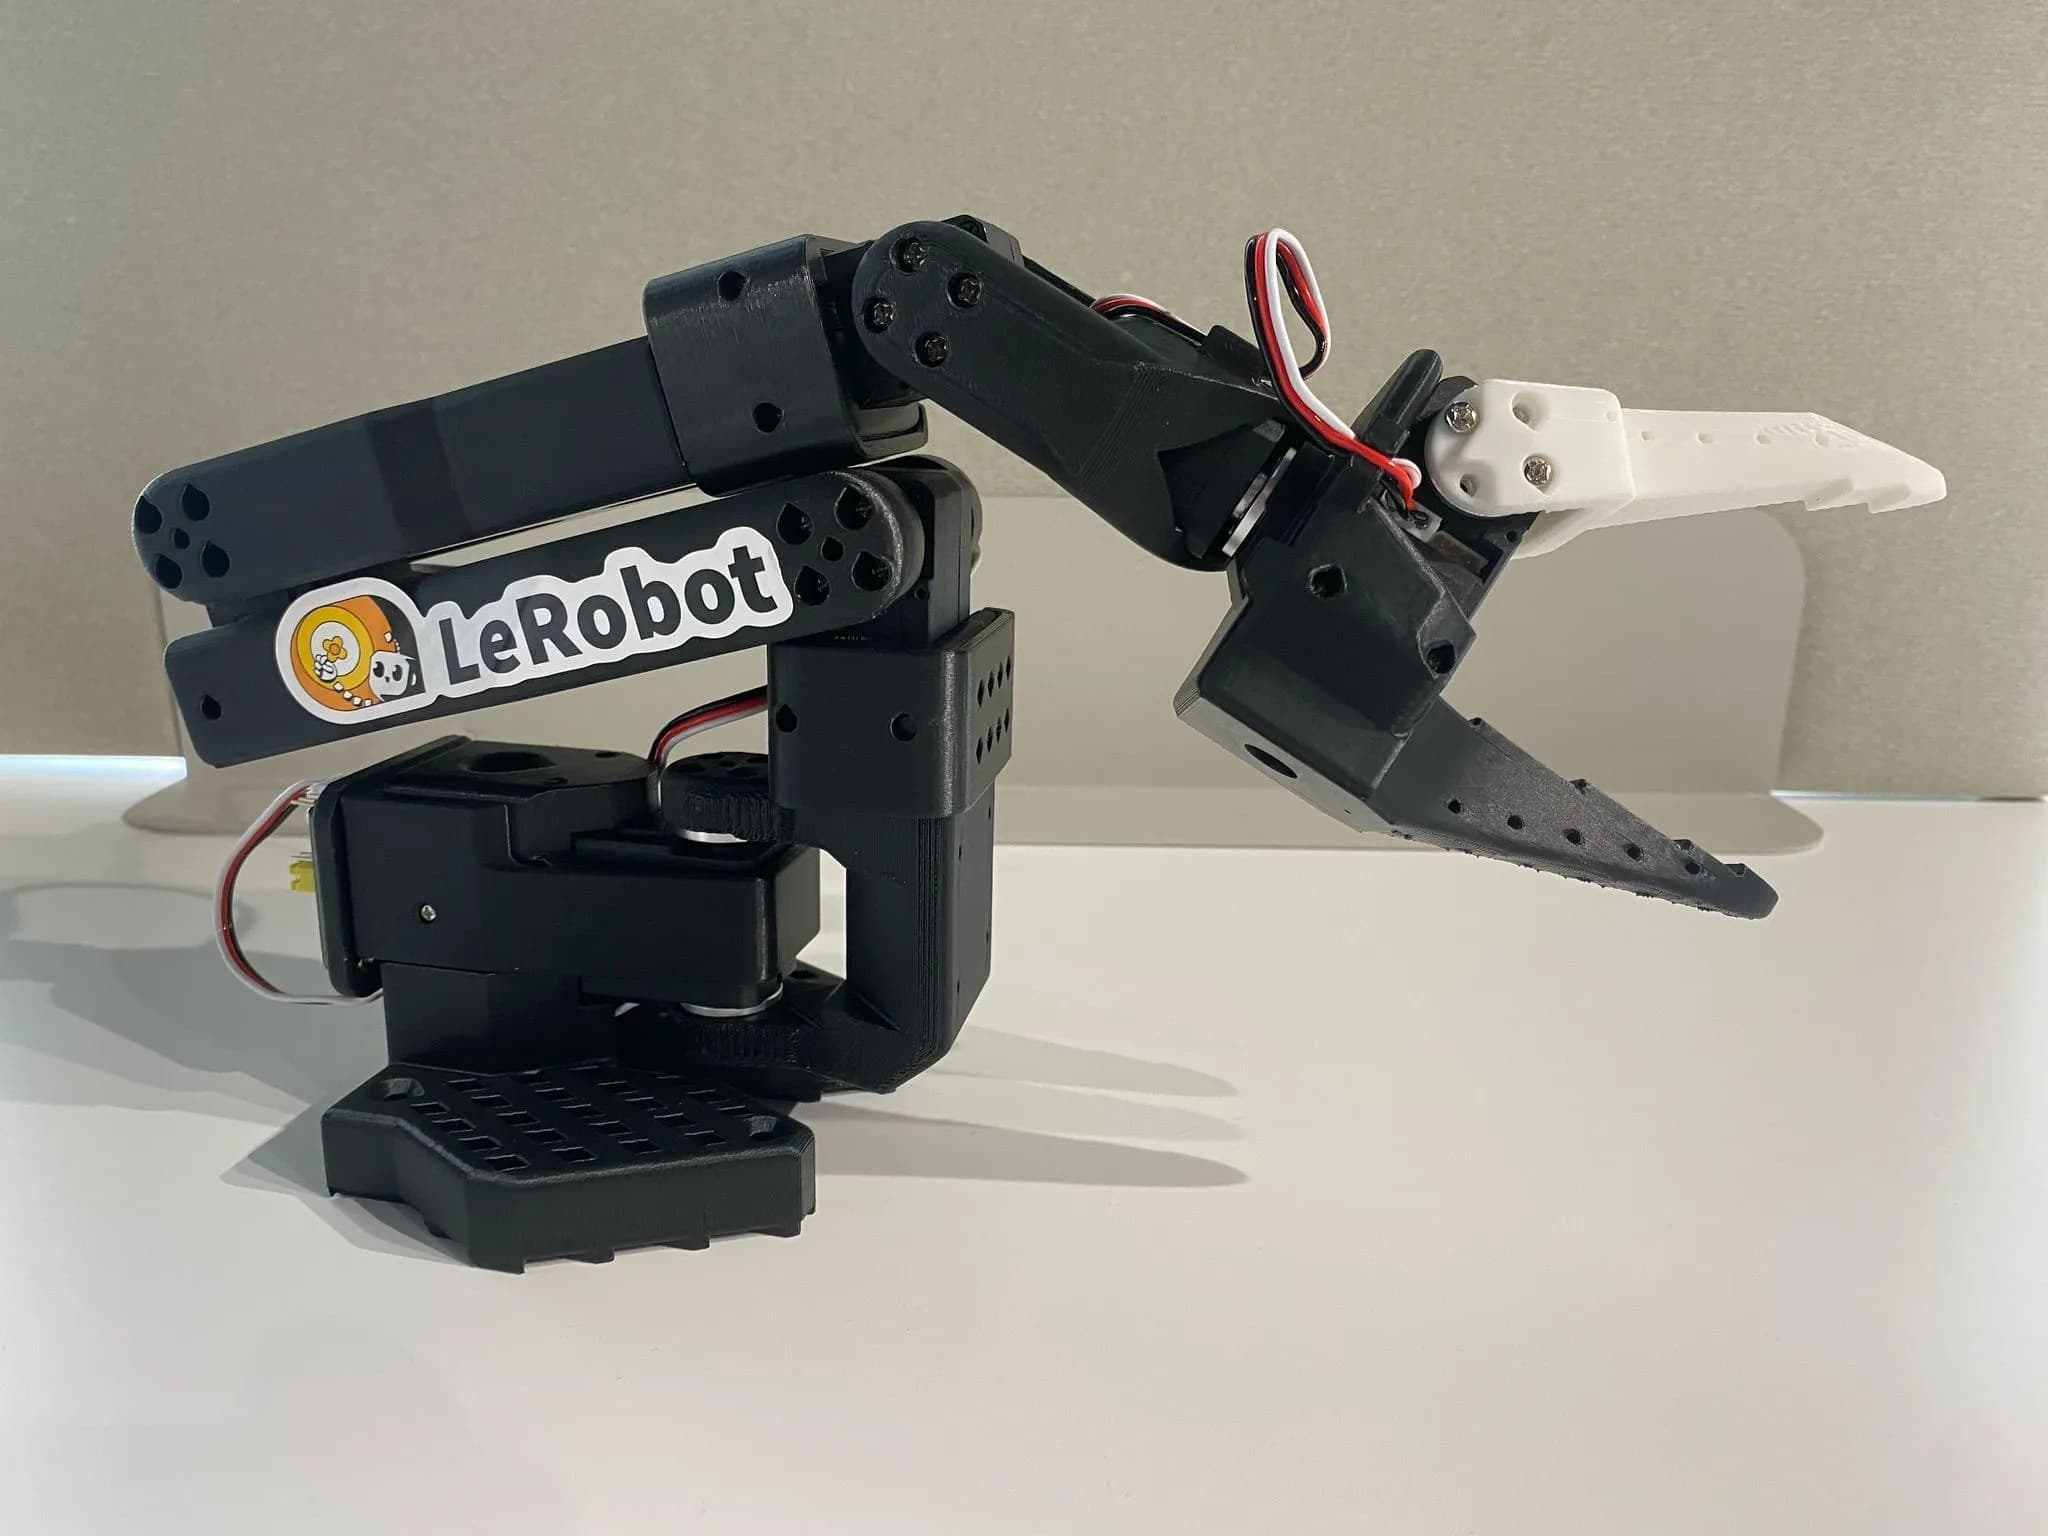
The Labelix.ai Robot Lab is a remote robot lab in Dhaka, Bangladesh, with its first SO-101 cell planned for December 2026. Test your robot policy on real hardware without building a lab: you bring the model, we run the arm, score every attempt and hand back the data in LeRobot format.
The test plan is free, and nothing is billed until you approve it.
- Live teleop
- Planned for Asia and the Gulf
- Overnight runs
- For the US and Europe
- Data out
- LeRobot format, yours to keep
- First cell
- Planned for December 2026
Our arm, or your robot. Same team, same scoring.
Book remote time on a real SO-101 in our Dhaka lab once the first cell opens (planned for December 2026), or keep your robot at your site and have our operators run it over a secure link. Either way, every attempt is scored the same way.
Use our arm
Run your policy remotely on a real SO-101 in Dhaka.
- Live control planned for Asia and the Gulf
- Queue runs overnight from the US and Europe
- Objects staged and reset for you
We run your robot
Your robot stays at your site. Our operators run it.
- Over a secure link, attempt after attempt
- Teleop demos or full test campaigns
- Same scoring as in the Robot Lab
You bring the model. We do everything around it.
A Labelix.ai engineer works with you, and the team behind them covers whatever the work needs, until you have an answer you can act on.
An engineer
A Labelix.ai engineer works directly with your team, from the first call to the last run.
Operators
Operators trained on your task, who teleoperate, reset the scene and record every attempt.
Review and QA
Every run scored, every failure tagged by cause, and a second check before anything ships.
Data
Episodes cleaned, labeled and delivered in LeRobot format, ready to train on.
From one line to real-robot results.
- 1
Tell us the task
One line is enough: the robot, the task and how you judge success.
- 2
Get a test plan
We send the setup, the number of runs and the price. Free, and no commitment.
- 3
The arm runs
Live with you on the line, or overnight while you sleep. Every attempt recorded.
- 4
Get answers back
Scored runs, failure clips tagged by cause, and the full dataset in LeRobot format.
Every run scored. Every failure explained.
Robot policy evaluation on real hardware: pass, partial or fail for each attempt, every takeover marked, the failure clips and the full dataset. Each failure is tagged by the layer where it began, so you know exactly what to fix.
Planning
Wrong object, wrong order, wrong place.
Control
Right plan, wrong motion: a missed grasp, a slip, an overshoot.
Safety
A stop or a takeover to protect the arm, the objects or a person.
Tasks we set up and score
- Pick and place into bins
- Sort and clear a table
- Fold cloth
- Insert, plug and assemble
- Pack a box, bag or kit
- Load and unload a machine
See your policy on a real arm.
Talk to an expertTalk to usBuilt for teams who need real-robot answers.
Robot learning startups
Check every model update on the same arm, scored the same way, before you buy hardware.
Researchers without a rig
Real-robot results for your paper on the SO-101, a popular arm in LeRobot community datasets.
Teams that need teleoperation data
Teleoperation data collection for your task: our operators record demonstrations on the SO-101, and only usable episodes count.
Schools and classes
A real arm for a robotics class, teleoperated and programmed from the classroom.
Start on the SO-101. Bring the arm you already run.
SO-101
Planned for December 2026: two leader and follower pairs, the leader arm for live teleop, the follower for your policy. The SO-100 and SO-101 family is one of the most common robots in LeRobot community datasets. SmolVLA was pretrained on data from its predecessor, the SO-100, and tested on the SO-101.
Not in the lab yet
We can add one of these for your project.
YAM, two-arm
I2RTA two-arm setup popular with robot learning startups.
Franka Research 3
Franka RoboticsFor policies trained on DROID or other Franka data.
SO-101, two-arm
Leader and follower pairsFor bimanual tasks such as folding.
Your robot, run by our operators
Your robot stays at your site and our operators run it over a secure link. Arms we can plan for include:
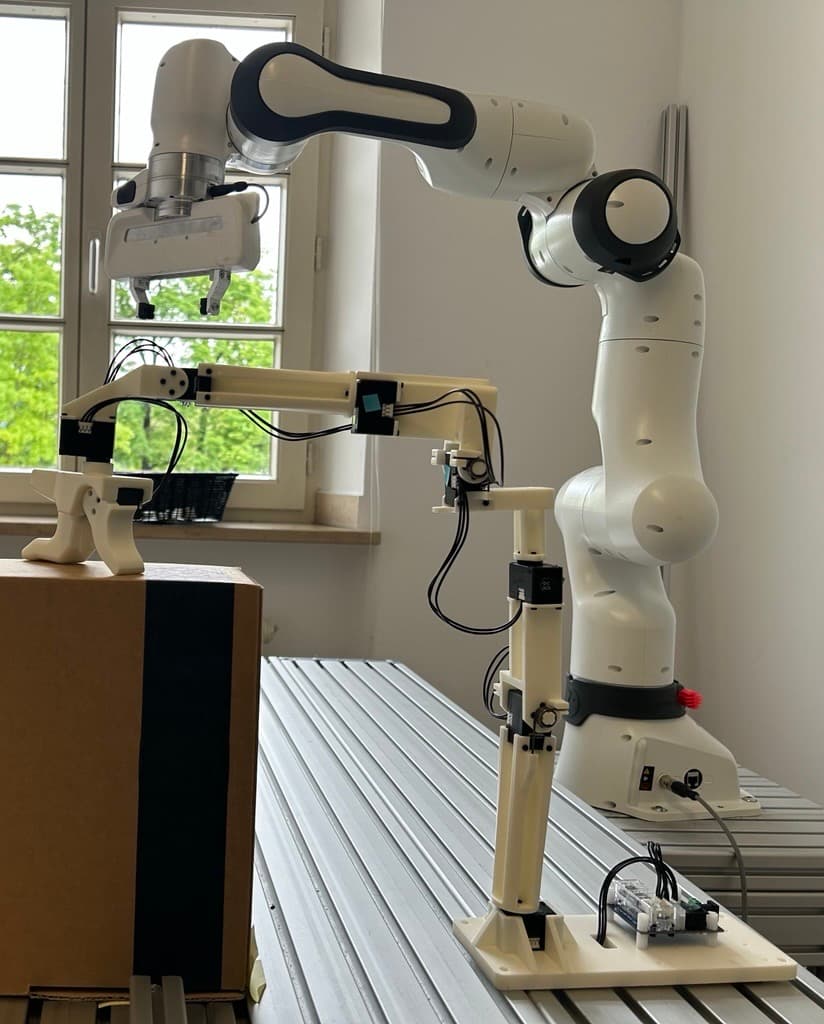
Franka Research 3
Franka RoboticsThe newer model of the Panda, the arm DROID was recorded on. Franka arms are the most common robots in Open X-Embodiment by number of datasets.
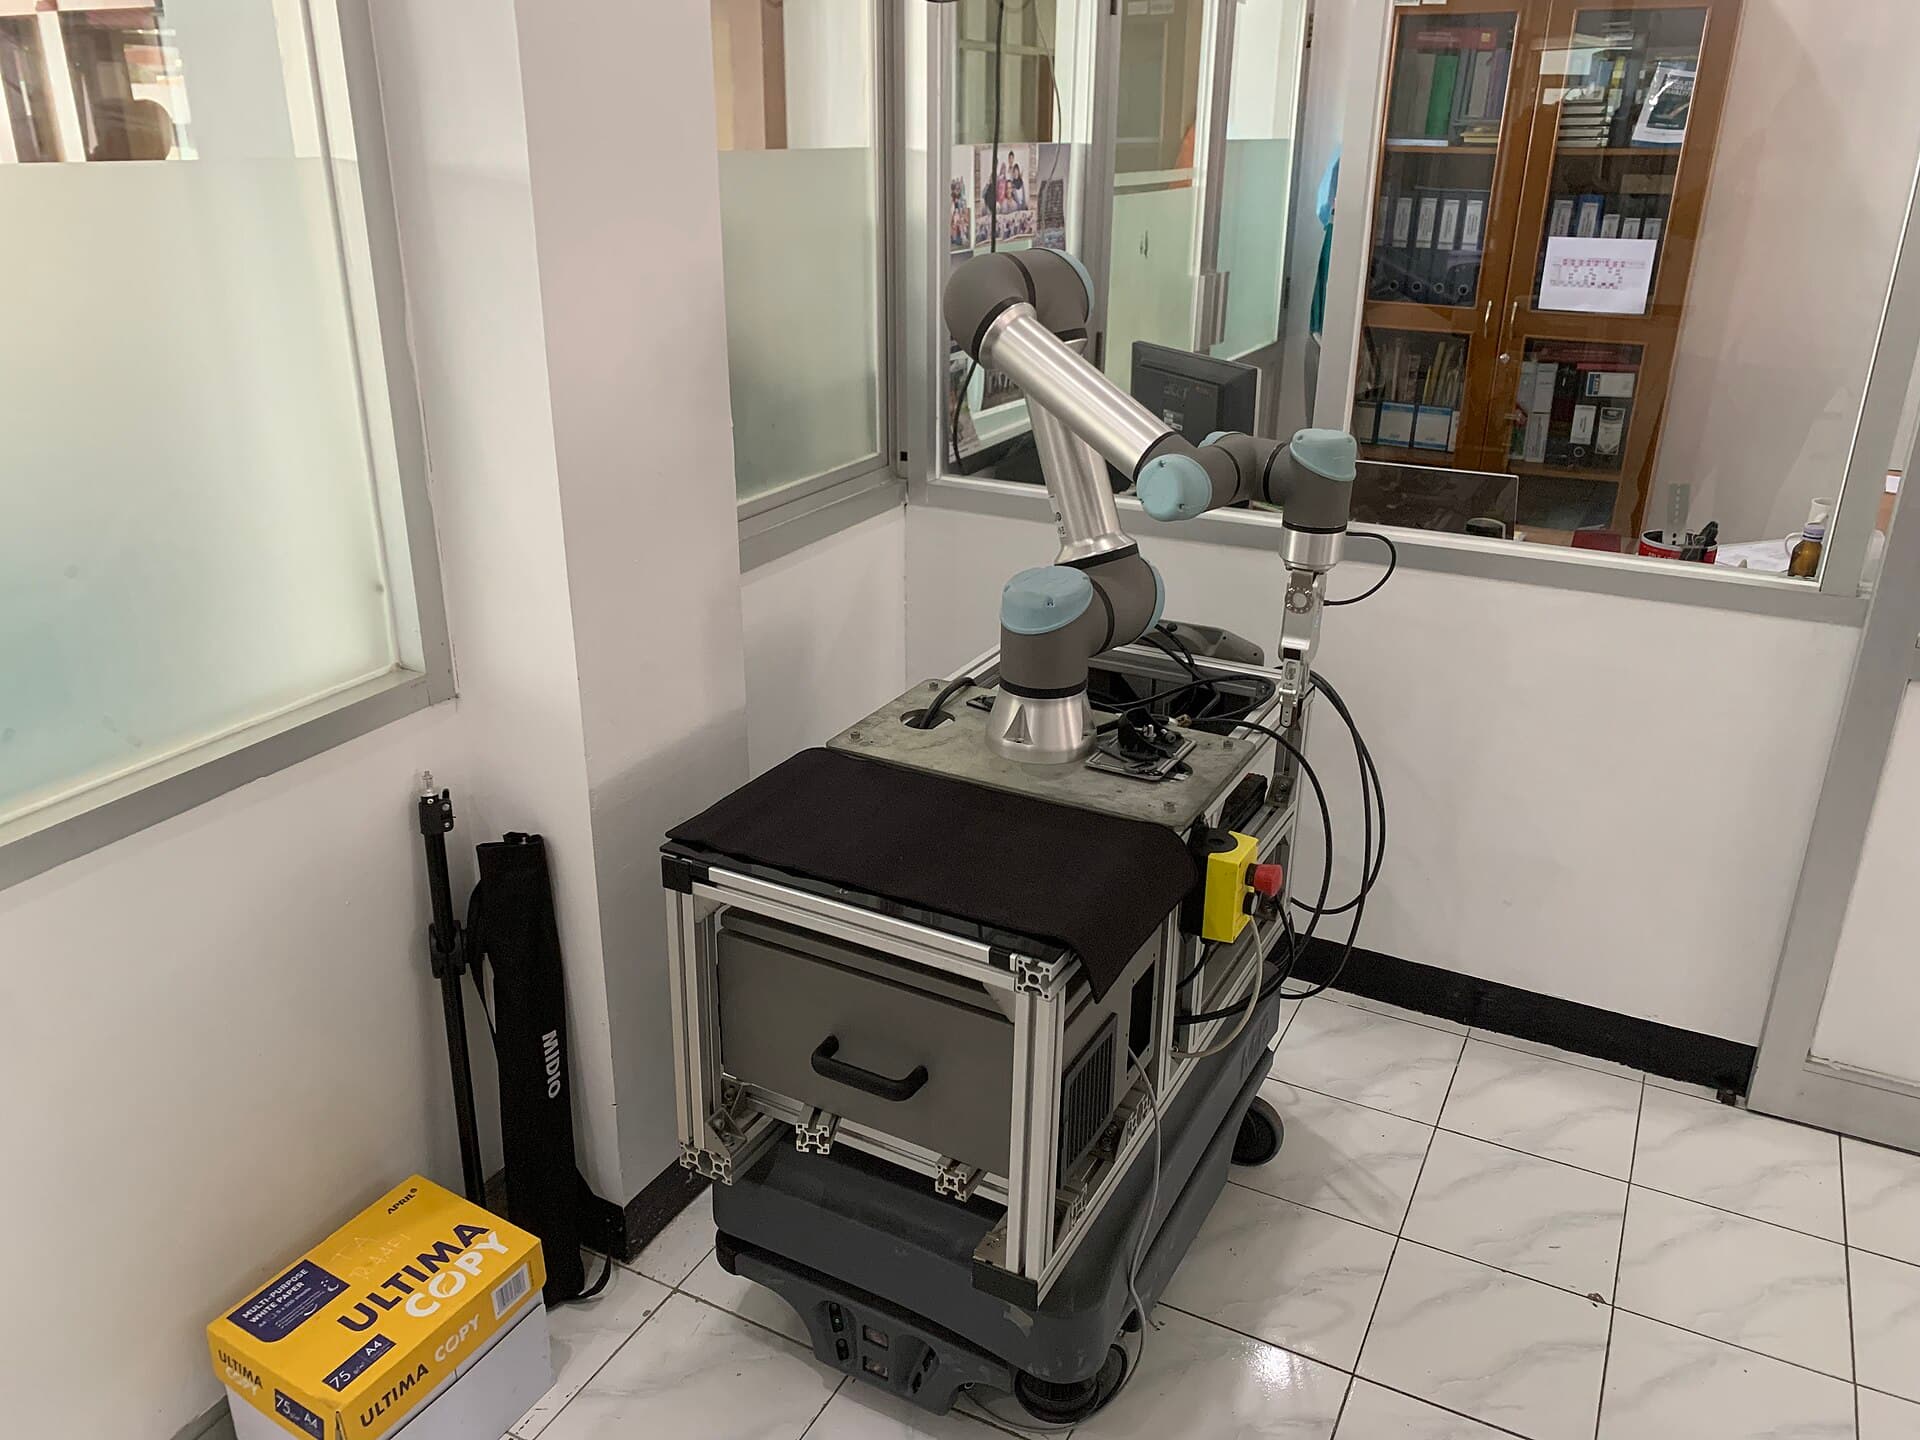
UR7e
Universal RobotsUniversal Robots' upgrade of the UR5e, the industrial cobot used in pi0's one-arm and two-arm setups.
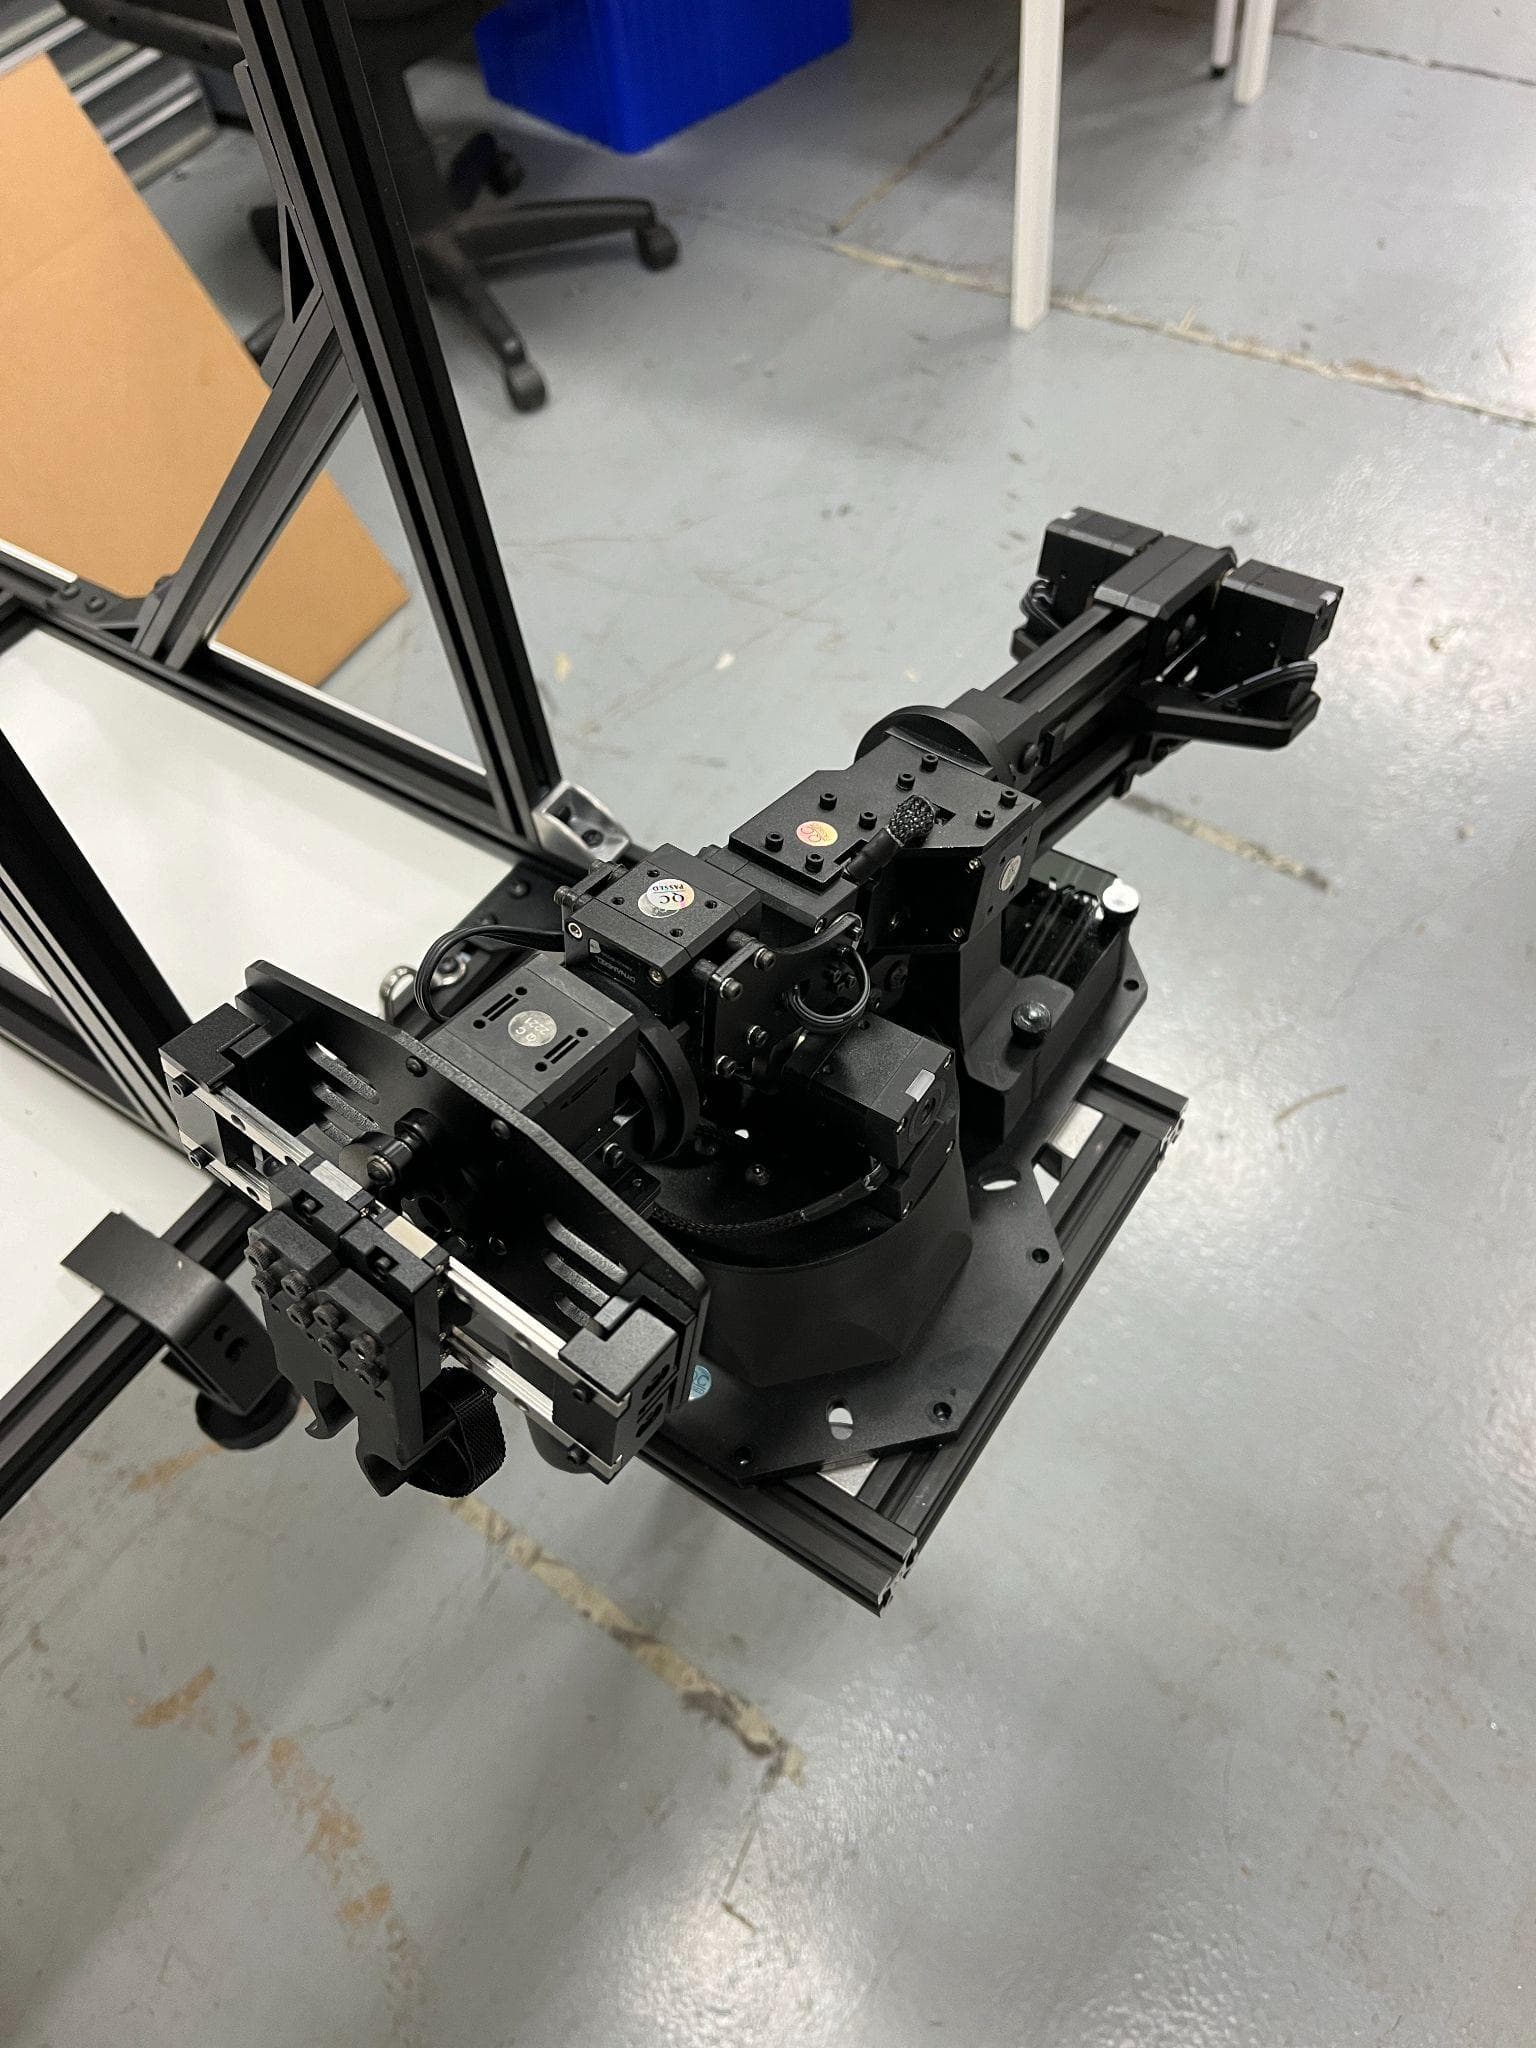
WidowX, ALOHA kit
Trossen RoboticsThe leader arm in Trossen's ALOHA kits, a common setup for two-arm research.
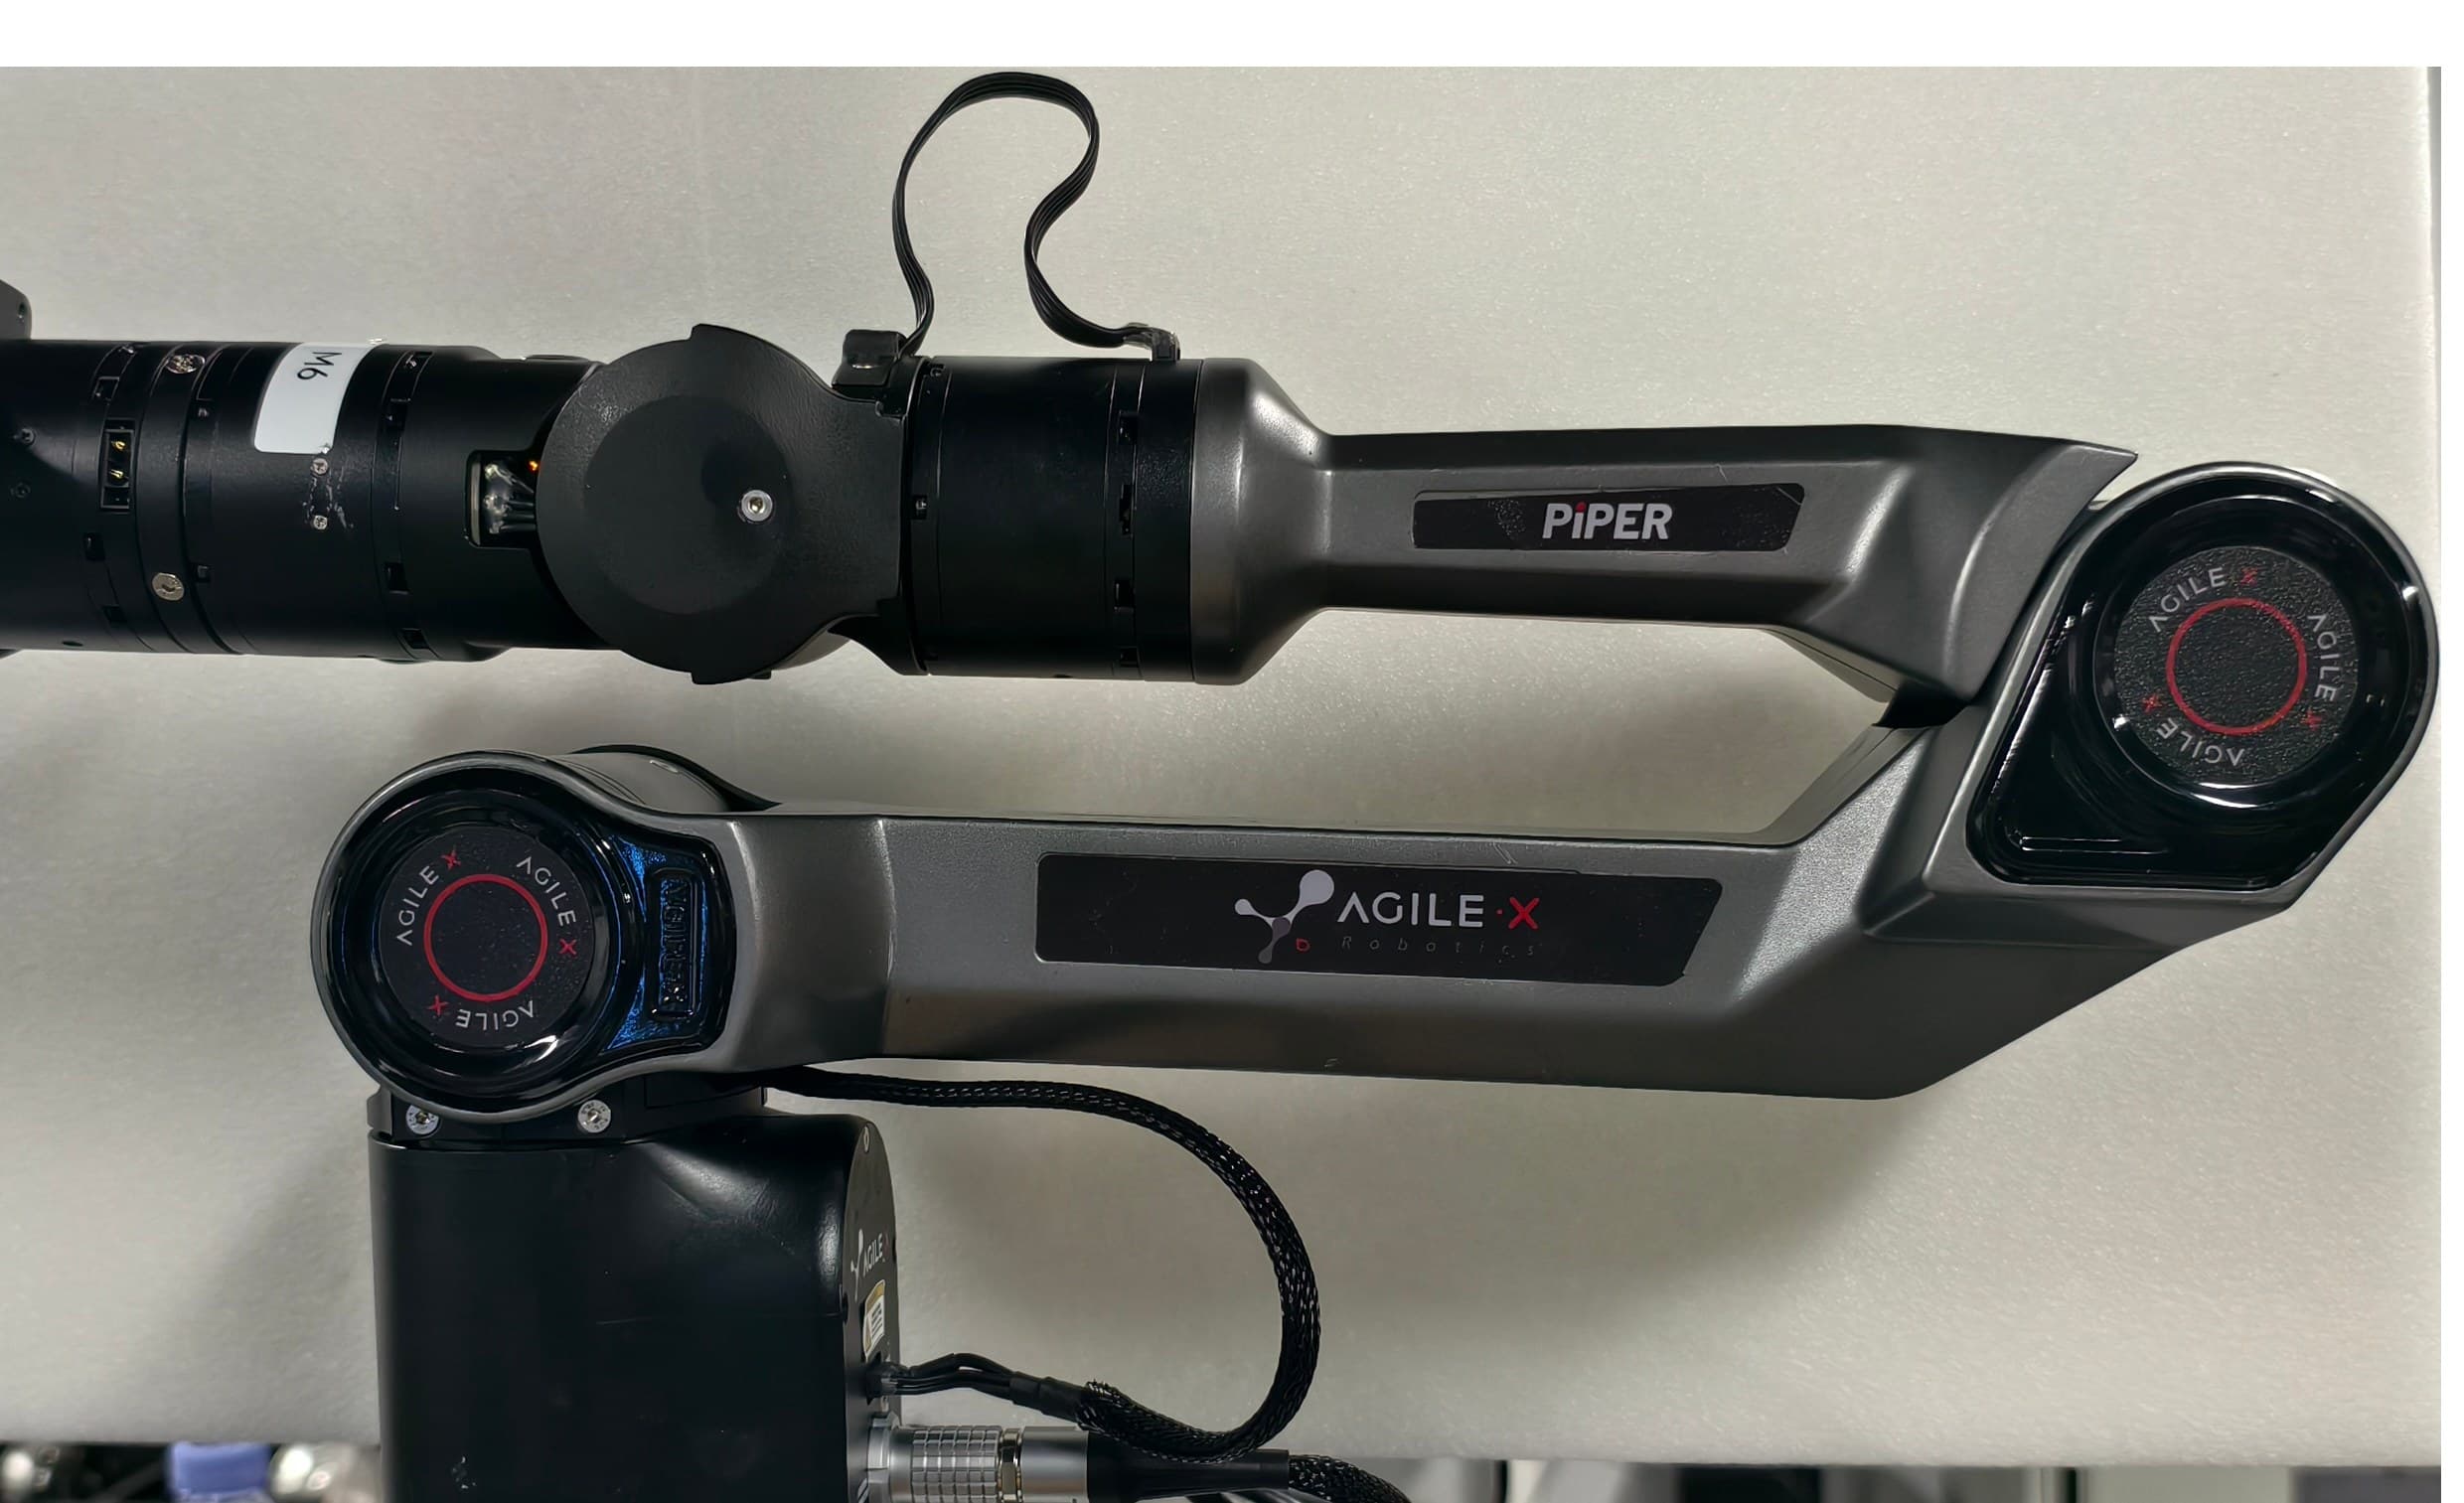
Labelix.ai is independent of every maker listed and is not paid by any of them.
Start small. Scale when it works.
Every project is priced in a written test plan for your task. Price on request, and nothing is billed until you approve it.
Feasibility Sprint
Can this task be learned? Your policy or our teleop demos on the SO-101 under 3 conditions, with scored runs, failure clips, a LeRobot dataset and a plain answer.
Use our arm
Join early access now; sessions start when the first SO-101 cell opens, planned for December 2026.
Arm session
Your own session on the SO-101: queue your policy runs from anywhere, with live teleoperation planned for Asia and the Gulf.
Price on requestTeleop data on SO-101
Our operators record demonstrations of your task on the SO-101.
Price on request
Bring your robot or your recordings
No arm of ours needed. Your robot stays at your site and our operators run it over a secure link.
Remote Standard Trial
Our operators run your task on your robot: 5 conditions, 30 attempts each.
Price on requestRemote operator block
A trained operator runs your robot over a secure link, by the hour.
Price on requestRecording Audit
Send 50 clips of your robot at work. We score each one.
Price on request
Schools and classes
A real arm for a robotics class, used from the classroom.
Arm class-hours
Students take turns teleoperating and programming the SO-101 during class.
Price on request
We run the robot. You keep the data and the models.
Your data stays yours
Your policy, your footage and the dataset belong to you, kept apart from other clients and deleted on request.
Nothing billed before you approve
Every project starts with a written test plan. You see the setup and the price first.
Independent
We don't resell robots and no maker pays us. If a maker ever commissions a test, the report says so on page one.
Labelix.ai Robot Lab FAQ
The Labelix.ai Robot Lab is a robot lab as a service run by Labelix.ai in Dhaka, Bangladesh. Teams will book remote sessions on real SO-101 robot arms, or have Labelix.ai operators run their own robot over a secure link, and get back scored runs, failure clips tagged by cause and a LeRobot dataset. The first SO-101 cell is planned to open in December 2026.
A Labelix.ai engineer works directly with your team. Around the arm, the same Labelix.ai team handles scoring, QA review, failure tagging, operators and data checks.
The first SO-101 cell is planned to open in December 2026. Join early access now and we confirm your date once the cell has passed our own tests. Work that needs no arm of ours, such as a Recording Audit or operators on your robot, can be planned sooner.
Live teleoperation is planned for teams in most of Asia and the Gulf, and we test the link with you before your first session. US and European teams usually queue overnight runs: send your policy at the end of your day, we run it while you sleep, and the aim is results waiting for you in the morning.
The simplest path to evaluate a LeRobot policy is one trained for the SO-101, shared as a Hugging Face repository or a checkpoint file, with a note on the cameras and objects it expects. We load it on the cell and run it. If your weights must stay on your side, we agree the setup with you in the test plan.
In the lab: SO-101 leader and follower arms, first cell planned for December 2026. Not in the lab yet: we can add a YAM from I2RT, a Franka Research 3 or a two-arm setup for your project. On your own robot: our operators can run arms that have a remote control or teleoperation interface, such as Franka, UR, ALOHA-style kits and PiPER. We confirm your setup in the test plan.
Your policy, your footage and the dataset are yours, kept separate from other clients, used only for your sessions and deleted on request.
Every run scored pass, partial or fail, every takeover marked, failure clips tagged by layer (planning, control or safety), and the full dataset in LeRobot format so you can train on it straight away.
Price on request. Every project is priced in a written test plan based on the task, the robot and the number of runs, and nothing is billed until you approve it.
No. Labelix.ai does not resell robots and none of the makers on this page pays us. If a maker ever commissions a test, the report says so on page one.
What are you training?
Tell us in one line. A Labelix.ai engineer replies with a test plan and a price. The first SO-101 cell is planned to open in December 2026.
More on robot testing and data
- Robot evaluation and benchmarking: how scored runs are designed and reported
- Robot failure analysis: every failure tagged by cause: planning, control or safety
- Physical AI data collection: teleoperation data for training robot policies
- Robot benchmark test design: tasks and scoring you can rerun every release
- How robot policy evaluation works: a guide to scoring real robot runs
- How to find robot failures in hours of video: from search to reviewed failures
- Sim-to-real robotics: why simulation results need real-robot checks
- Imitation learning and teleoperation: how demonstrations become training data
- Robot failure analysis, the guide: how to learn from robot policy failures
- Robot benchmark design: test scenarios that reflect real-world performance
- What makes a robotics dataset usable: why only usable episodes count
- All Labelix.ai solutions: annotation, Physical AI data and robot evaluation