All articles
Page 3 of 3. Back to the latest
Articles, page 3
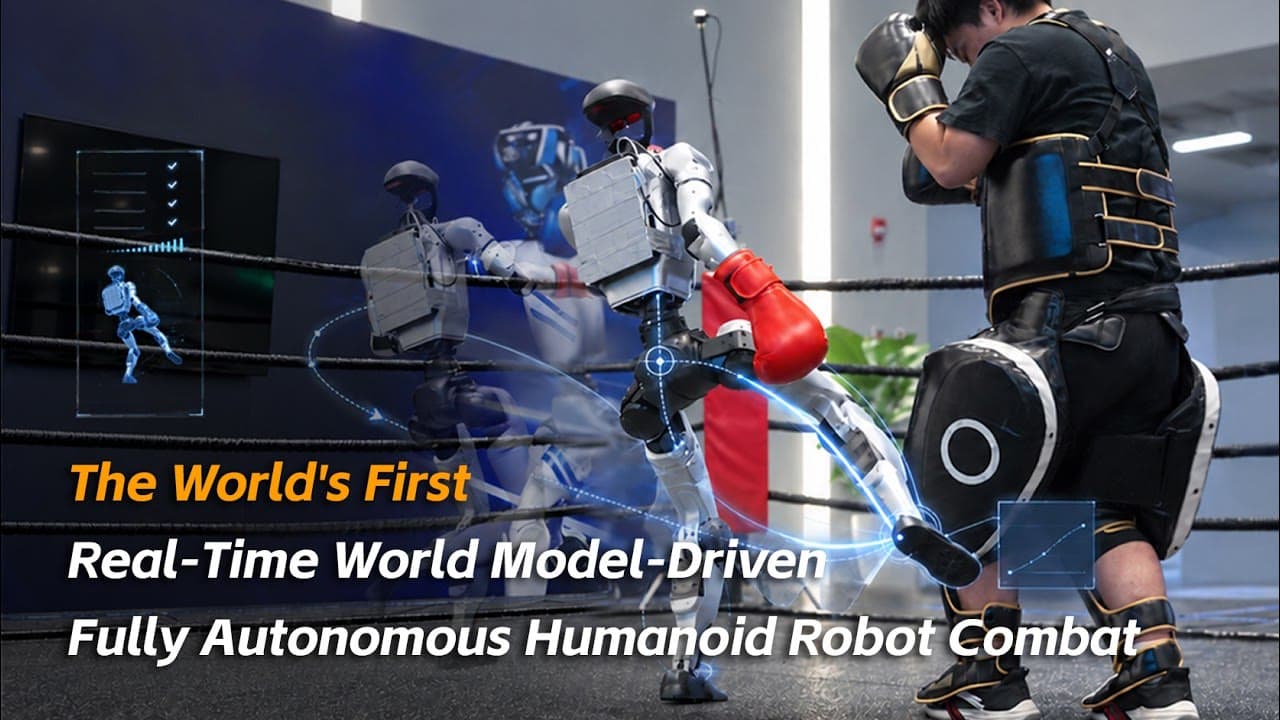
This Week in Robotics: Sep 7-13, 2026
A humanoid that spars with no one at the controls, a $100 million warehouse robot raise, Samsung reorganizing to build its own humanoid, and a fresh bet on the layer beneath every robot.
 Cindy DizonRead the article →
What Kind of Data Do Robots Need? It Depends Where They're Working
A warehouse robot and a home robot aren't learning from the same data. How training data requirements shift by deployment environment, and what stays constant no matter where a robot works.
Cindy DizonRead the article →
This Week in Robotics: Aug 31-Sep 6, 2026
Nscale bets $3.5B of compute on Figure, a dual-arm robot ties rebar on a building site, Medtronic puts $700M into surgical robotics, and Nvidia pushes real inference to the edge.
Cindy DizonRead the article →
What Is Robotics Data Annotation? A Guide to Labeling Robot Training Data
Robot recordings capture behavior that unfolds over time. Annotation is what turns that into actions, states, events and outcomes a learning system can use.
Cindy DizonRead the article →
This Week in Robotics: Aug 24-30, 2026
Skild's S1 learns from one video, Figure scales human data with Index, humanoids race in Beijing, and XPENG raises to build IRON.
Cindy DizonRead the article →
Sim-to-Real in Robotics: Where Simulated Data Helps and Where It Breaks
Simulation can accelerate robot training, but the physical world doesn't follow the rules of a simulator. Here's where simulated data works, where the reality gap appears, and why real-world data still matters.
Cindy DizonRead the article →
What Makes a Robotics Dataset Actually Usable?
Diversity, sensor coverage, and consistent annotation matter more than raw volume. Here's how to tell if a dataset can actually teach a robot.
Cindy DizonRead the article →
Imitation Learning vs. Teleoperation: How Robots Learn Real-World Skills
From observation to operation: how robots acquire real-world skills.
Cindy DizonRead the article →
What Is Physical AI? Why Data Will Decide the Humanoid Robotics Race
Robots don't have to learn every job from scratch. They start with us.
Cindy DizonRead the article →